12-Amethyst
Sep 7, 2018 6:50 PM UTC
Solved

Can a PID motor control be implemented in CREO mechanism?

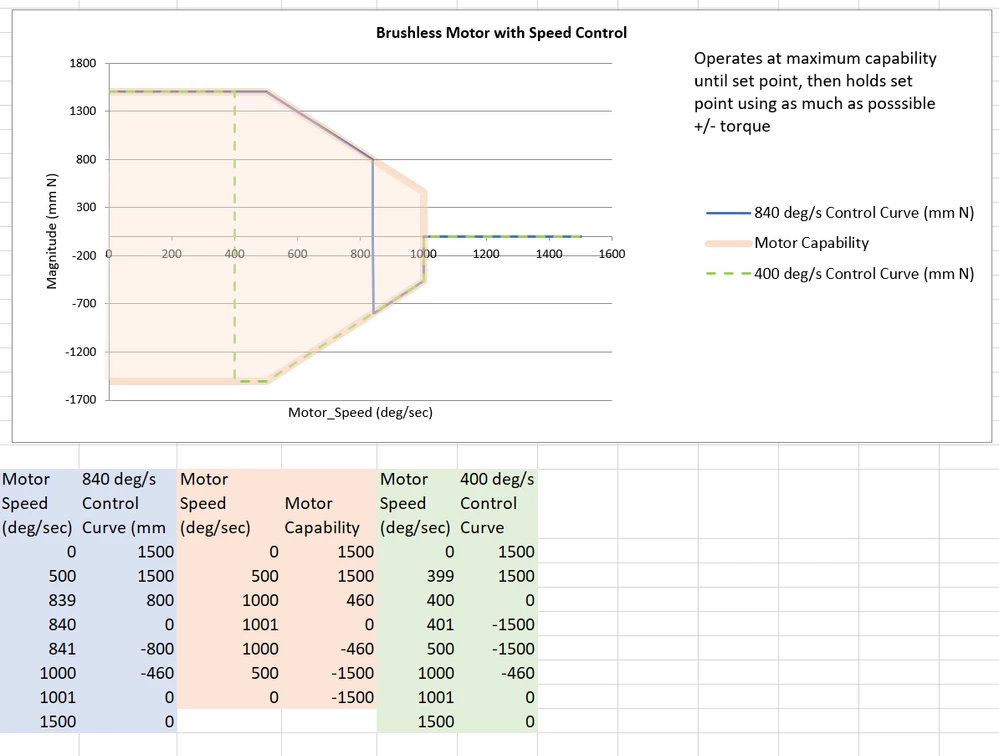
Is it possible to implement a PID (Proportional - Integral - Derivative) speed or position control on a motor in CREO mechanism?  Here is an example of a basic (non PID) speed control I have used with a torque motor.  What if there is a specific algorithm used by the control circuit such as PID?  Are there some example of how this might be implemented?  Is Custom Loads a possible or preferred way to do this?
 

Torque Motor Speed Control MethodTorque Motor Speed Control Method


16-Pearl
Sep 18, 2018 8:51 PM UTC

Yes, you can! There was an old example model that PTC posted many years ago when the tool was "Mechanica Applied Motion". I have used this same model to have it run properly in Creo 5...at least it appears to run properly, as I haven't checked the details of all results to know it's accurate. I have attached a PDF of the original paper posted many years ago and my comments on how this should be modified to get the desired result in Creo (even those are old now!). The model is also attached (Creo 2 version).


Enjoy,


Chris

9 replies

17-Peridot
Sep 7, 2018 6:54 PM UTC

Sorry, this is me. I used the wrong login.

Translate
16-Pearl
Sep 18, 2018 8:51 PM UTC

Yes, you can! There was an old example model that PTC posted many years ago when the tool was "Mechanica Applied Motion". I have used this same model to have it run properly in Creo 5...at least it appears to run properly, as I haven't checked the details of all results to know it's accurate. I have attached a PDF of the original paper posted many years ago and my comments on how this should be modified to get the desired result in Creo (even those are old now!). The model is also attached (Creo 2 version).


Enjoy,


Chris

Translate
17-Peridot
Sep 21, 2018 7:24 AM UTC

Hi,
I wonder how one can limit the torque of the motor (in plus and minus).
I worked on your model and I saw that If I add only 1 torque motor, instead of 3, who is commanded by a user defined measure (that is the sum of the measur of the 3 troque motors) I have the same behavior as before.
2.JPG
But if I try to limit this new motor (-600<=total torque<=+600) the system doesn't respond well.
Cattura.JPG
What am I doing wrong?

Translate
12-Amethyst
Sep 21, 2018 4:15 PM UTC

Did you try adjusting the gains?  Particularly the integral gain should be reduced for a saturated system.

Translate